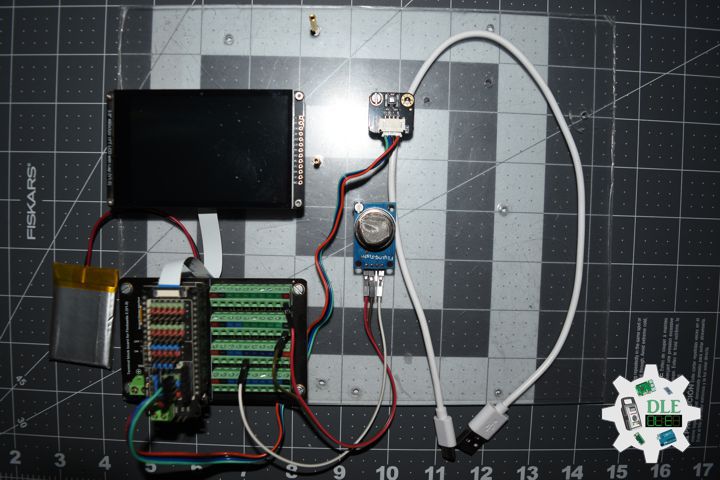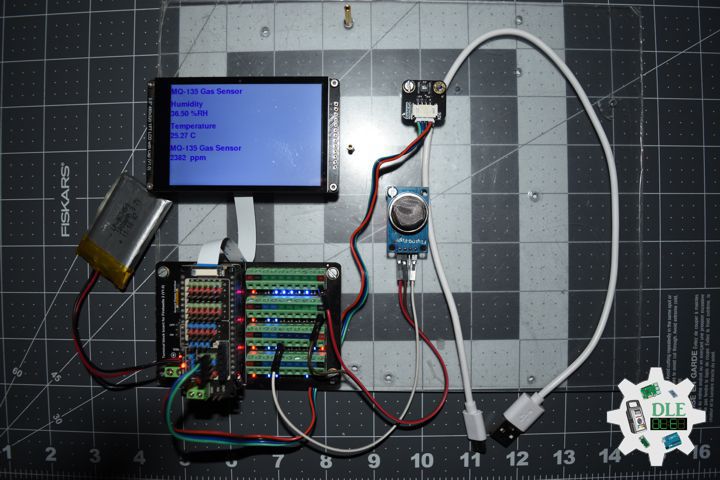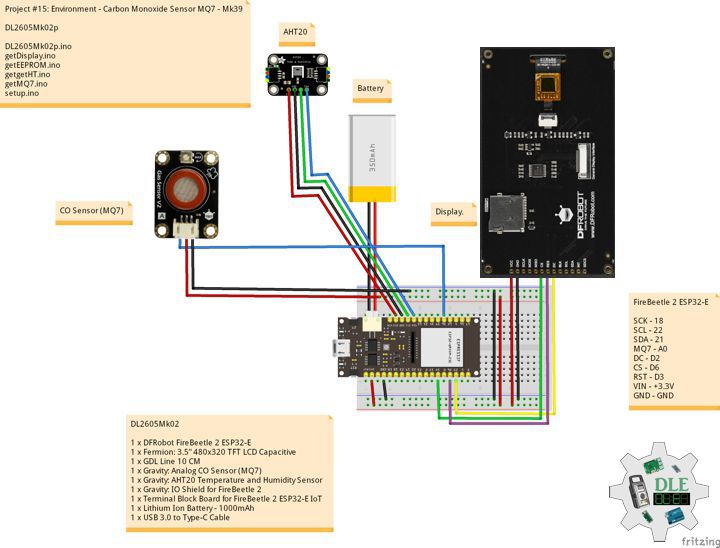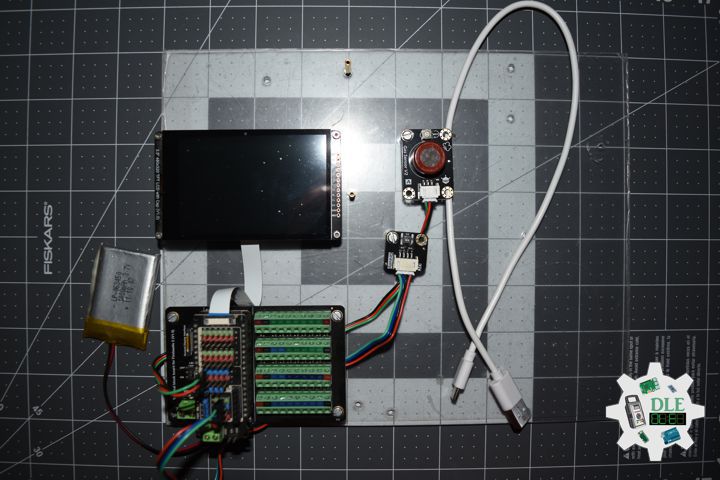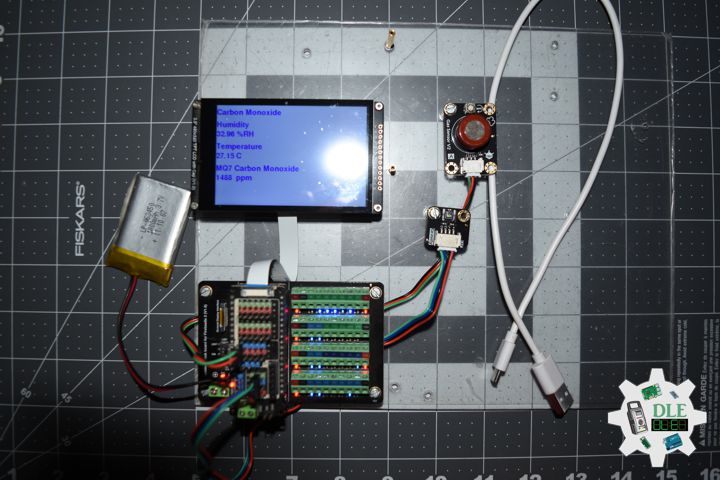
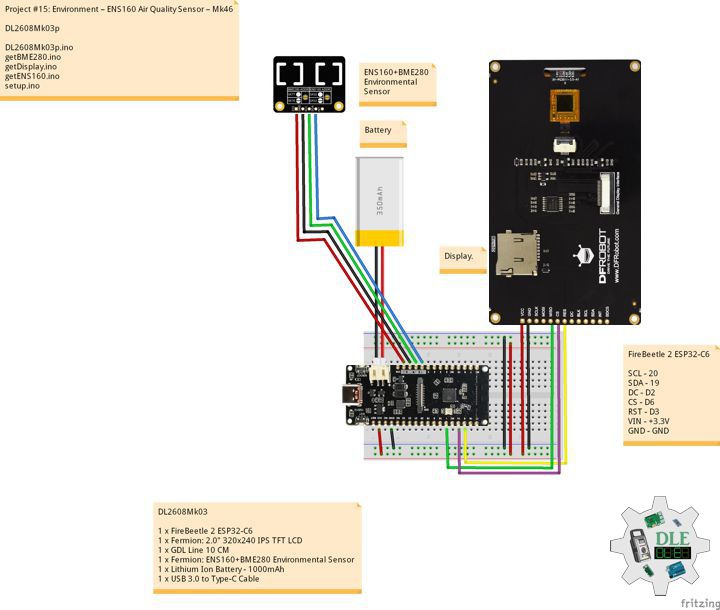
Project #15: Environment – ENS160 Air Quality Sensor – Mk46

——

#DonLucElectronics #DonLuc #ENS160 #BME280 #Environment #FireBeetle2ESP32C6 #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——
ENS160 Air Quality Sensor

——

ENS160 Air Quality Sensor

——

ENS160 Air Quality Sensor

——

ENS160 Air Quality Sensor

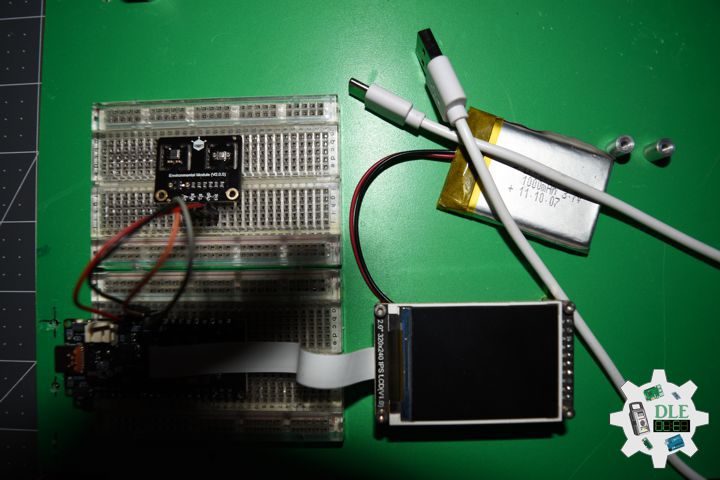
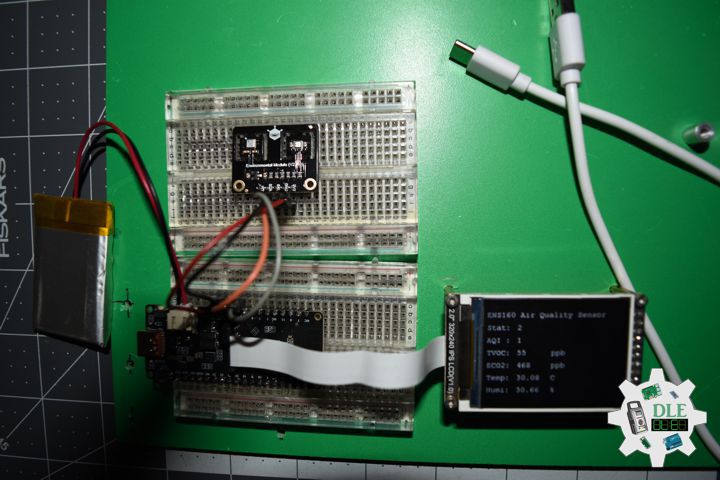
This Gravity: ENS160 Air Quality Sensor, based on ScioSense’s new ENS160 sensor chip, is specifically designed for indoor air quality monitoring and offers detection of multiple IAQ data (TVOC, eCO2, AQI). The innovative TrueVOC™ technology combines the metal oxide (MOX) technology that brings this sensor superior accuracy, fast response, anti-interference, etc. With intelligent on-chip algorithms, the ENS160 can directly output rich and easy-to-understand environmental data. Preheat the sensor 3 minutes before use then you can obtain accurate data more quickly. What’s more, the built-in automatic baseline correction algorithm ensures the long-term stability of the sensor.

DL2608Mk03

1 x FireBeetle 2 ESP32-C6
1 x Fermion: 2.0″ 320×240 IPS TFT LCD
1 x GDL Line 10 CM
1 x Fermion: ENS160+BME280 Environmental Sensor
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2608Mk03p

DL2608Mk03p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – ENS160 Air Quality Sensor – Mk46
15-46
DL2608Mk03p.ino
DL2608Mk03
1 x FireBeetle 2 ESP32-C6
1 x Fermion: 2.0" 320x240 IPS TFT LCD
1 x GDL Line 10 CM
1 x Fermion: ENS160+BME280 Environmental Sensor
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// BME280 Environmental
#include <DFRobot_BME280.h>
// ENS160 Air Quality Sensor
#include <DFRobot_ENS160.h>

// ENS160 Air Quality Sensor
// I2C communication.
#define I2C_COMMUNICATION  
// I2C address is 0x53
DFRobot_ENS160_I2C ENS160(&Wire, 0x53);
// Status
uint8_t Status;
// AQI
uint8_t AQI;
// TVOC
uint16_t TVOC;
// ECO2
uint16_t ECO2;

// BME280 Environmental
typedef DFRobot_BME280_IIC BME;
// Wire
BME   bme(&Wire, 0x76);
// Sea Level Pressure
#define SEA_LEVEL_PRESSURE 1015.0f
// Temperature
float   temp = bme.getTemperature();
// Pressure
uint32_t    press = bme.getPressure();
// Altitude
float alti;
// Humidity
float humi;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 240x320
DFRobot_ST7789_240x320_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-46";

void loop() {
  
  // isBME280
  isBME280();
  
  // isENS160
  isENS160();
  
  // isDisplay ENS160
  isDisplayENS160();

  // Delay 1 Second
  delay( 1000 );
  
}

getBME280.ino

// BME280 Environmental
// isBME280
void isBME280(){

  // Temperature
  temp = bme.getTemperature();
  // Pressure
  press = bme.getPressure();
  // Altitude
  alti = bme.calAltitude(SEA_LEVEL_PRESSURE, press);
  // Humidity
  humi = bme.getHumidity();

}

getDisplay.ino

// DFRobot Display 240x320
// DFRobot Display 240x320 - UID
void isDisplayUID(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Mono 9pt
  screen.setFont(&FreeMono9pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // BME280 Environmental
  screen.setCursor(0, 60);
  screen.println("ENS160 Air Quality Sensor");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay ENS160
void isDisplayENS160(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Mono 9pt
  screen.setFont(&FreeMono9pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // ENS160 Air Quality Sensor
  screen.setCursor(0, 30);
  screen.println("ENS160 Air Quality Sensor");
  // AQI
  screen.setCursor(0, 60);
  screen.print("AQI : ");
  screen.setCursor(70, 60);
  screen.println( AQI );
  // TVOC
  screen.setCursor(0, 90);
  screen.print("TVOC: ");
  screen.setCursor(70, 90);
  screen.print( TVOC );
  screen.setCursor(150, 90);
  screen.println( "ppb" );
  // ECO2
  screen.setCursor(0, 120);
  screen.print("ECO2: ");
  screen.setCursor(70, 120);
  screen.print( ECO2 );
  screen.setCursor(150, 120);
  screen.println( "ppb" );
  // Temperature
  screen.setCursor(0, 150);
  screen.print("Temp: ");
  screen.setCursor(70, 150);
  screen.print( temp );
  screen.setCursor(150, 150);
  screen.println( "C" );
  // Humidity
  screen.setCursor(0, 180);
  screen.print("Humi: ");
  screen.setCursor(70, 180);
  screen.print( humi );
  screen.setCursor(150, 180);
  screen.println( "%" );

}

getENS160.ino

// ENS160 Air Quality Sensor
// isENS160
void isENS160(){

  // Status - Return value: 0-Normal operation 1-Warm-Up phase 
  // 2-Initial Start-Up phase
  Status = ENS160.getENS160Status();

  // AQI - Return value: 1-Excellent, 2-Good, 3-Moderate, 4-Poor, 5-Unhealthy
  AQI = ENS160.getAQI();

  // TVOC - Return value range: 0–65000, unit: ppb
  TVOC = ENS160.getTVOC();

  // ECO2 = Return value range: 400–65000, unit: ppm
  // Five levels: Excellent(400 - 600), Good(600 - 800), Moderate(800 - 1000), 
  // Poor(1000 - 1500), Unhealthy(> 1500)
  ECO2 = ENS160.getECO2();

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay(100);

  // DFRobot Display 128x160
  screen.begin();

  // Delay
  delay( 100 );

  // BME280 Environmental
  bme.begin();

  // Delay
  delay( 100 );

  // ENS160 Air Quality Sensor
  ENS160.begin();
  /**
   * Set power mode
   * mode Configurable power mode:
   * ENS160_SLEEP_MODE: DEEP SLEEP mode (low power standby)
   * ENS160_IDLE_MODE: IDLE mode (low-power)
   * ENS160_STANDARD_MODE: STANDARD Gas Sensing Modes
   */
  ENS160.setPWRMode(ENS160_STANDARD_MODE);

  /**
   * Users write ambient temperature and relative humidity into ENS160 for
   * calibration and compensation of the measured gas data.
   * ambientTemp Compensate the current ambient temperature, float type, unit: C
   * relativeHumidity Compensate the current ambient humidity, float type, unit: %rH
   * Temperature
   * Humidity=
   */
  ENS160.setTempAndHum(temp, humi);

  // Delay
  delay( 100 );

  // DFRobot Display 240x320 - UID
  // Don Luc Electronics
  // Versioc
  isDisplayUID();
  
  // Delay
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
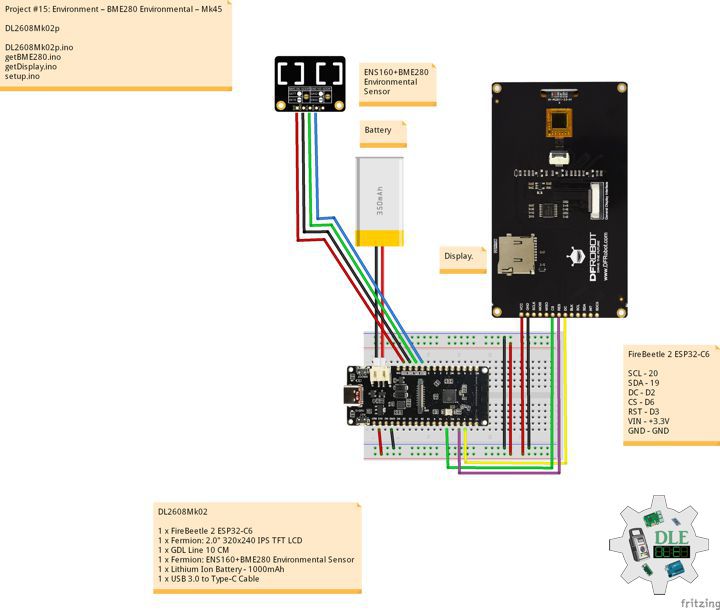
Project #15: Environment – BME280 Environmental – Mk45

——

#DonLucElectronics #DonLuc #BME280 #Environment #FireBeetle2ESP32C6 #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

BME280 Environmental

——

BME280 Environmental

——

BME280 Environmental

——

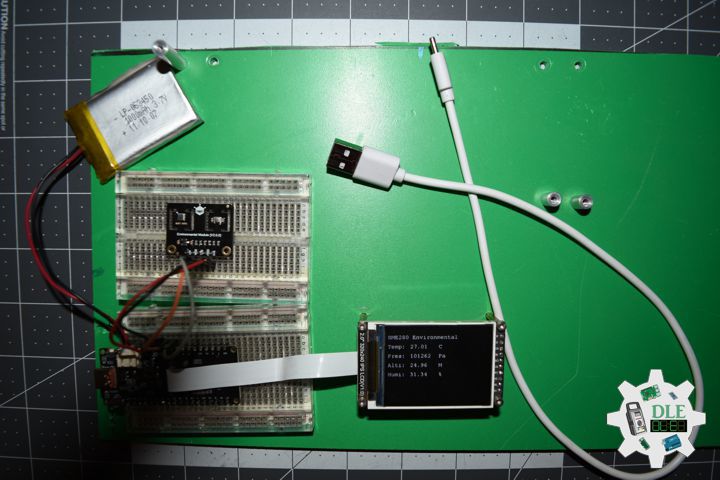
Fermion: ENS160+BME280 Environmental Sensor

BME280 is an environmental sensor that integrates onboard temperature sensor, humidity sensor and barometer. The sensor is of high precision, multiple functions, and small size etc. It provides both SPI and I2C interfaces, which make it easy to make a fast prototypes. It can be widely used in environmental monitoring, story height measurement and Internet of Things (IoT) control and so on. Gravity I2C BME280 Environmental Sensor has based on BoSCH newest MEMS sensor. Therefore, the stable and multi-function make BME280 become a good choice in many scenes.

DL2608Mk02

1 x FireBeetle 2 ESP32-C6
1 x Fermion: 2.0″ 320×240 IPS TFT LCD
1 x GDL Line 10 CM
1 x Fermion: ENS160+BME280 Environmental Sensor
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2608Mk02p

DL2608Mk02p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – BME280 Environmental – Mk45
15-45
DL2608Mk02p.ino
DL2608Mk02
1 x FireBeetle 2 ESP32-C6
1 x Fermion: 2.0" 320x240 IPS TFT LCD
1 x GDL Line 10 CM
1 x Fermion: ENS160+BME280 Environmental Sensor
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// BME280 Environmental
#include <DFRobot_BME280.h>

// BME280 Environmental
typedef DFRobot_BME280_IIC BME;
// Wire
BME   bme(&Wire, 0x76);
// Sea Level Pressure
#define SEA_LEVEL_PRESSURE 1015.0f
// Temperature
float   temp = bme.getTemperature();
// Pressure
uint32_t    press = bme.getPressure();
// Altitude
float alti;
// Humidity
float humi;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 240x320
DFRobot_ST7789_240x320_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-45";

void loop() {
  
  // isBME280
  isBME280();
  
  // isDisplay BME280
  isDisplayBME280();

  // Delay 1 Second
  delay( 1000 );
  
}

getBME280.ino

// BME280 Environmental
// isBME280
void isBME280(){

  // Temperature
  temp = bme.getTemperature();
  // Pressure
  press = bme.getPressure();
  // Altitude
  alti = bme.calAltitude(SEA_LEVEL_PRESSURE, press);
  // Humidity
  humi = bme.getHumidity();

}

getDisplay.ino

// DFRobot Display 240x320
// DFRobot Display 240x320 - UID
void isDisplayUID(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Mono 9pt
  screen.setFont(&FreeMono9pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // BME280 Environmental
  screen.setCursor(0, 60);
  screen.println("BME280 Environmental");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay BME280
void isDisplayBME280(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Mono 9pt
  screen.setFont(&FreeMono9pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // BME280 Environmental
  screen.setCursor(0, 30);
  screen.println("BME280 Environmental");
  // Temperature
  screen.setCursor(0, 60);
  screen.print("Temp: ");
  screen.setCursor(70, 60);
  screen.print( temp );
  screen.setCursor(160, 60);
  screen.println( "°C" );
  // Pressure
  screen.setCursor(0, 90);
  screen.print("Pres: ");
  screen.setCursor(70, 90);
  screen.print( press );
  screen.setCursor(160, 90);
  screen.println( "Pa" );
  // Altitude
  screen.setCursor(0, 120);
  screen.print("Alti: ");
  screen.setCursor(70, 120);
  screen.print( alti );
  screen.setCursor(160, 120);
  screen.println( "M" );
  // Humidity
  screen.setCursor(0, 150);
  screen.print("Humi: ");
  screen.setCursor(70, 150);
  screen.print( humi );
  screen.setCursor(160, 150);
  screen.println( "%" );

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay(100);

  // DFRobot Display 128x160
  screen.begin();

  // Delay
  delay( 100 );

  // BME280 Environmental
  bme.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 240x320 - UID
  // Don Luc Electronics
  // Versioc
  isDisplayUID();
  
  // Delay
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
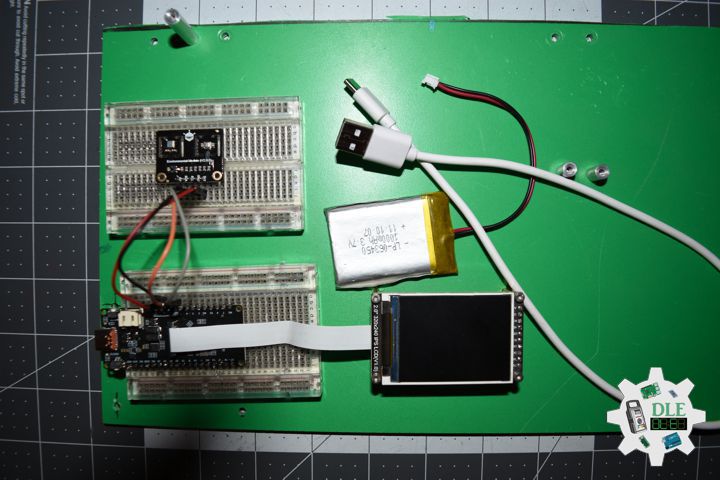
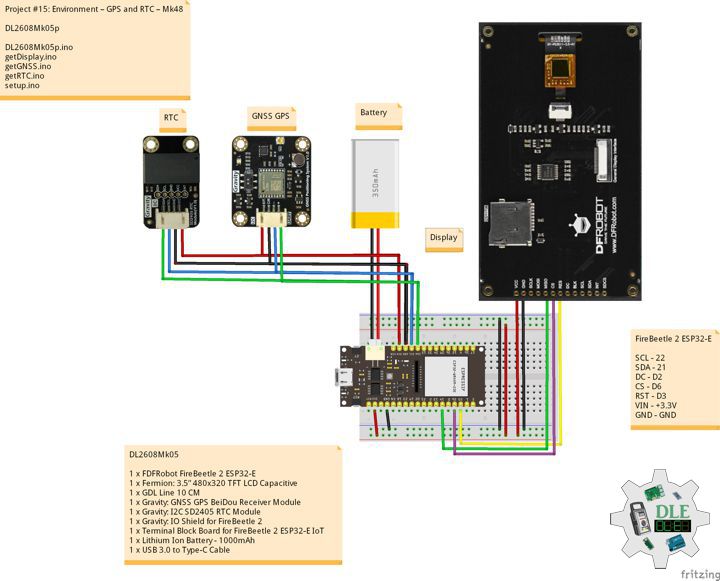
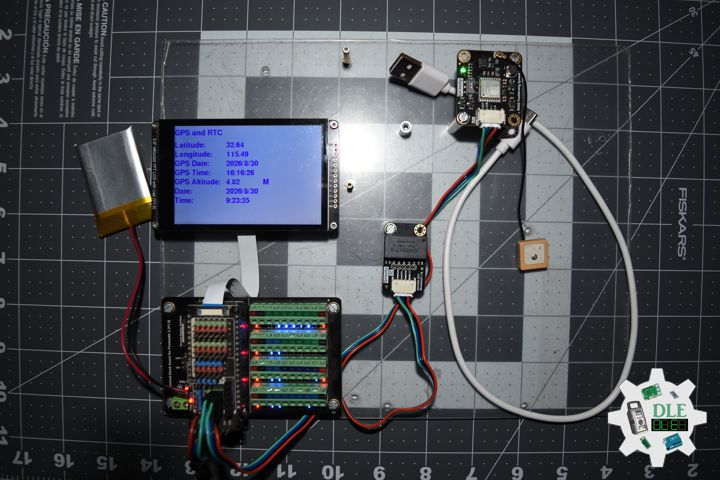
Project #15: Environment – GPS and RTC – Mk48

——

#DonLucElectronics #DonLuc #GPS #RTC #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——-

GPS and RTC

——

GPS and RTC

——

GPS and RTC

——

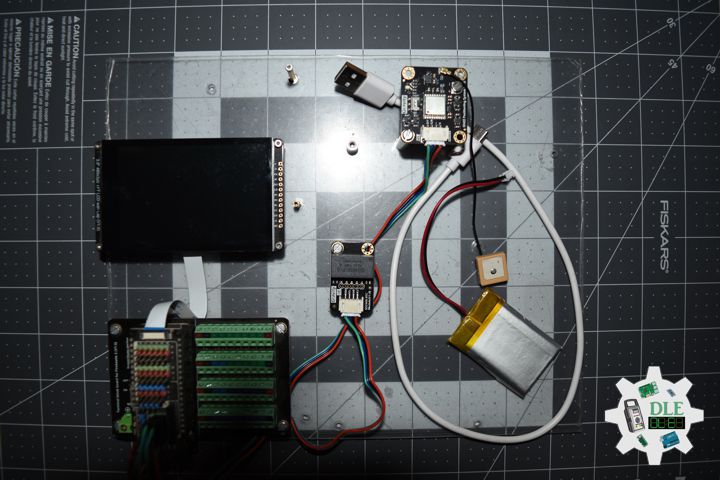
Gravity: GNSS GPS BeiDou Receiver Module

The GNSS receiver module supports multiple satellite systems for accurate, high-speed positioning in various environments. It’s compatible with I2C/UART devices. GNSS stands for Global Navigation Satellite System. The main GNSS systems include GPS, GLONASS, QZSS, and BeiDou. These satellite systems transmit signals to the earth, allowing the receiver to determine its own position by calculating the propagation time of the signals and the position of the receiving satellite, thus achieving functions such as positioning and navigation.

Gravity: I2C SD2405 RTC Module

The I2C SD2405 RTC module features accurate real-time clock, dual power supply, low power consumption, periodic interrupts, and a high precision time trimming circuit. The SD2405AL is dual power supply system. When the primary power supply goes down to an assigned value or resumes from low power, the system can switch between the primary power supply and battery automatically. Even there is no external power, it can still work for 5~8 years, 1uA ultra-low power consumption.

DL2608Mk05

1 x FDFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: GNSS GPS BeiDou Receiver Module
1 x Gravity: I2C SD2405 RTC Module
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2608Mk05p

DL2608Mk05p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – GPS and RTC – Mk48
15-48
DL2608Mk05p.ino
DL2608Mk05
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: GNSS GPS BeiDou Receiver Module
1 x Gravity: I2C SD2405 RTC Module
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// GNSS GPS
#include <DFRobot_GNSS.h>
// RTC (Real-Time Clock)
#include "GravityRtc.h"

// RTC Initialization
GravityRtc rtc;
// Date and Time
String dateRTC = "";
String timeRTC = "";

// GNSS GPS
// Use I2C for communication, but use the serial port for
// communication if the line of codes were masked
#define I2C_COMMUNICATION
// ESP32 user hardware uart
DFRobot_GNSS_I2C gnss(&Wire, GNSS_DEVICE_ADDR);
String sDate = "";
String sUTC = "";
String sLat = "";
String sLon = "";
String sAlt = "";

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-48";

void loop() {
  
  // isGNSS
  isGNSS();

  // RTC (Real-Time Clock)
  isRTC();

  // isDisplay GPS RTC
  isDisplayGPSRTC();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("GPS and RTC");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay GPS RTC
void isDisplayGPSRTC(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // IP65 Capacitive Soil Moisture Sensor
  screen.setCursor(0, 30);
  screen.println("GPS and RTC");
  // Latitude
  screen.setCursor(0, 70);
  screen.println("Latitude: ");
  screen.setCursor(170, 70);
  screen.println( sLat );
  // Longitude
  screen.setCursor(0, 100);
  screen.print("Longitude: ");
  screen.setCursor(170, 100);
  screen.println( sLon );
  // GPS Date
  screen.setCursor(0, 130);
  screen.println("GPS Date: ");
  screen.setCursor(170, 130);
  screen.println( sDate );
  // GPS Time
  screen.setCursor(0, 160);
  screen.println("GPS Time: ");
  screen.setCursor(170, 160);
  screen.println( sUTC );
  // Altitude
  screen.setCursor(0, 190);
  screen.println("GPS Altitude: ");
  screen.setCursor(170, 190);
  screen.print( sAlt );
  screen.setCursor(290, 190);
  screen.println( "M" );
  // Date
  screen.setCursor(0, 220);
  screen.println("Date: ");
  screen.setCursor(170, 220);
  screen.println( dateRTC );
  // Time
  screen.setCursor(0, 250);
  screen.println("Time: ");
  screen.setCursor(170, 250);
  screen.println( timeRTC );
  
}

getGNSS.ino

// GNSS
// isSetupGNSS
void isSetupGNSS(){
  
  // GNSS
  gnss.begin();
  
  // GNSS
  gnss.enablePower();      
/** Set the galaxy to be used
 *   eGPS              USE gps
 *   eBeiDou           USE beidou
 *   eGPS_BeiDou       USE gps + beidou
 *   eGLONASS          USE glonass
 *   eGPS_GLONASS      USE gps + glonass
 *   eBeiDou_GLONASS   USE beidou +glonass
 *   eGPS_BeiDou_GLONASS USE gps + beidou + glonass
 */
  gnss.setGnss(eGPS_BeiDou_GLONASS);
  // GNSS
  // gnss.setRgbOff();
  gnss.setRgbOn();
  
}
// isGNSS
void isGNSS(){

  // GNSS
  sTim_t utc = gnss.getUTC();
  sTim_t date = gnss.getDate();
  sLonLat_t lat = gnss.getLat();
  sLonLat_t lon = gnss.getLon();
  double high = gnss.getAlt();
  
  sDate = "";
  sUTC = "";
  sLat = "";
  sLon = "";
  sAlt = "";
  // Latitude
  sLat = lat.latitudeDegree;
  // Longitude
  sLon = lon.lonitudeDegree;
  // Date
  sDate = date.year;
  sDate = sDate + "/";
  sDate = sDate + date.month;
  sDate = sDate + "/";
  sDate = sDate + date.date;
  // UTC
  sUTC = utc.hour;
  sUTC = sUTC + ":";
  sUTC = sUTC + utc.hour;
  sUTC = sUTC + ":";
  sUTC = sUTC + utc.minute;
  // Altitude
  sAlt = high;

}

getRTC.ino

// Real-Time Tlock
// Date and Time RTC
void isRTC () {

  // Date and Time
  dateRTC = "";
  timeRTC = "";
  rtc.read();
  
  // Date
  dateRTC = rtc.year; 
  dateRTC = dateRTC + "/";
  dateRTC = dateRTC + rtc.month;
  dateRTC = dateRTC + "/";
  dateRTC = dateRTC + rtc.day;

  // Time
  timeRTC = rtc.hour;
  timeRTC = timeRTC + ":";
  timeRTC = timeRTC + rtc.minute;
  timeRTC = timeRTC + ":";
  timeRTC = timeRTC + rtc.second;
  
}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

  // isSetupGNSS
  isSetupGNSS();

  // Delay
  delay(100);

  // Setup RTC
  rtc.setup();

  //Set the RTC time automatically: Calibrate RTC time by your computer time
  rtc.adjustRtc(F(__DATE__), F(__TIME__));

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
Project #15: Environment – IP65 Capacitive Soil Moisture Sensor – Mk44

——

#DonLucElectronics #DonLuc #IP65SoilMoisture #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

IP65 Capacitive Soil Moisture Sensor

——

IP65 Capacitive Soil Moisture Sensor

——

IP65 Capacitive Soil Moisture Sensor

——

Gravity: IP65 Capacitive Soil Moisture Sensor

The Gravity Capacitive Soil Moisture Sensor offers IP65 waterproof protection and corrosion resistance, designed for long-term outdoor gardening, automated irrigation systems, and environmental science projects. Using advanced capacitive sensing technology, it outperforms traditional resistive sensors with higher accuracy and durability in humid or wet soil. This sensor provides an analog output signal, ensuring reliable moisture monitoring for optimal plant health in harsh outdoor conditions like balconies, gardens, and farms.

DL2607Mk01

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: IP65 Capacitive Soil Moisture Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2607Mk01p

DL2607Mk01p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – IP65 Capacitive Soil Moisture Sensor – Mk44
15-44
DL2607Mk01p.ino
DL2607Mk01
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: IP65 Capacitive Soil Moisture Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// IP65 Capacitive Soil Moisture Sensor
int iSoilMoisture = A0;
// You need to change this value that you had recorded in the air
const int AirValue = 570; 
// You need to change this value that you had recorded in the water
const int WaterValue = 39;
// Intervals
int intervals = (AirValue - WaterValue)/3;
int soilMoistureValue = 0;
// sVal
String sVal = "";

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-44";

void loop() {
  
  // isIP65
  isIP65();

  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay HTS
  isDisplayHTS();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("IP65 Capacitive Soil Moisture Sensor");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay HTS
void isDisplayHTS(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // IP65 Capacitive Soil Moisture Sensor
  screen.setCursor(0, 30);
  screen.println("IP65 Capacitive Soil Moisture Sensor");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // Soil Moisture
  screen.setCursor(0, 210);
  screen.println("Soil Moisture");
  screen.setCursor(0, 240);
  screen.println( sVal );

}

getHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

getIP65.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
Project #15: Environment – Steam Sensor – Mk43

——

#DonLucElectronics #DonLuc #Steam #AHT20 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

Steam Sensor

——

Steam Sensor

——

Steam Sensor

——

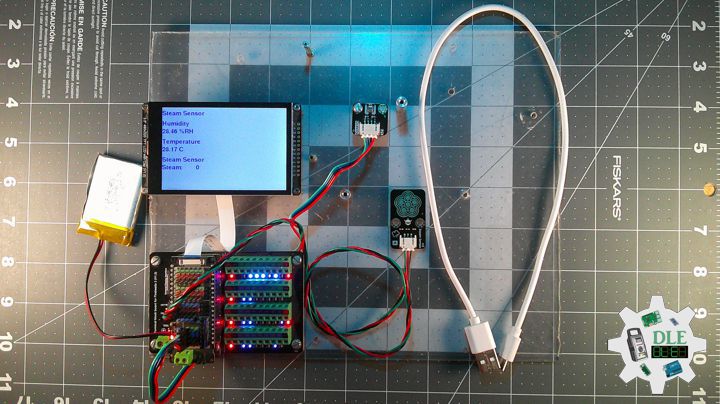
Gravity: Steam Sensor

DFRobot Steam Sensor is an analog moisture detection module designed to sense the presence of water droplets, steam, or surface humidity. The sensing board produces an analog voltage output that increases as moisture accumulates on the detection surface, enabling simple environmental monitoring and liquid detection projects. Direct compatibility with Arduino IO expansion shields simplifies wiring and rapid prototyping. This compact humidity-sensitive detection board provides an inexpensive solution for rain detection, condensation monitoring, and basic fluid presence sensing in electronics experiments, robotics projects, and educational demonstrations.

DL2606Mk05

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Steam Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2606Mk05p

DL2606Mk05p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment - Steam Sensor - Mk43
15-43
DL2606Mk05p.ino
DL2606k05
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Steam Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>
// Wire
#include <Wire.h>

// Steam Sensor
int iSteam = A0;
int iVal;

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "15-43";

void loop() {
  
  // Steam Sensor
  isSteam();
  
  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay Steam Sensor
  isDisplaySteam();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("Steam Sensor");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay Steam Sensor
void isDisplaySteam(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("Steam Sensor");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // Steam Sensor
  screen.setCursor(0, 210);
  screen.println("Steam Sensor");
  screen.setCursor(0, 240);
  screen.print( "Steam: " );
  screen.setCursor(130, 240);
  screen.println( iVal );

}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getgetHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

getSteam.ino

// Steam Sensor
// isSteam
void isSteam(){

  // Steam Sensor
  iVal = analogRead(iSteam);

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
Project #15: Environment – Infrared Temperature Sensor MLX90614 – Mk42

——

#DonLucElectronics #DonLuc #MLX90614 #AHT20 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

MLX90614

——

MLX90614

——

MLX90614

——

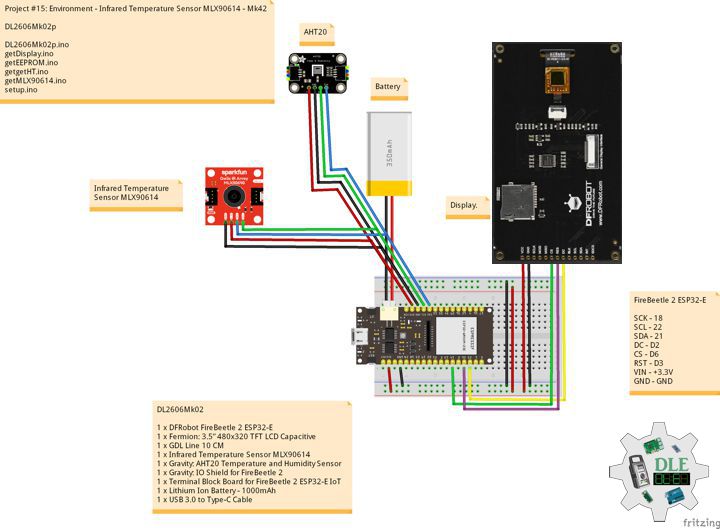
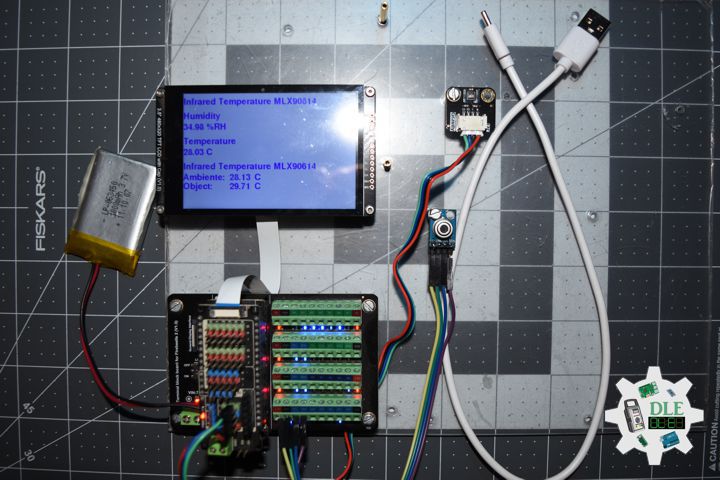
Infrared Temperature Sensor MLX90614

The MLX90614 infrared temperature sensor is a digital device that allows for contactless temperature measurement using the infrared radiation emitted by objects. This module integrates the Melexis MLX90614 sensor, which includes a thermopile to detect IR radiation and an internal processor that converts this signal into compensated temperature values for both the object and the ambient temperature. Its operation is based on the principle that all bodies emit infrared radiation proportional to their temperature; the sensor captures this radiation and translates it into a precise digital value. The MLX90614 offers measurements from -70 °C to 380 °C for object temperature and from -40 °C to 170 °C for ambient temperature, with a typical accuracy of ±0.5 °C. It primarily communicates via I2C facilitating its integration with microcontrollers.

The MLX90614 infrared temperature sensor is used in applications requiring contactless temperature measurement, making it ideal for digital thermometers, medical monitoring, temperature control in machinery, industrial systems, ovens, smart appliances, weather stations, and robotics projects.

DL2606Mk02

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Infrared Temperature Sensor MLX90614
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2606Mk02p

DL2606Mk02p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment - Infrared Temperature Sensor MLX90614 - Mk42
15-42
DL2606Mk02p.ino
DL2606k02
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Infrared Temperature Sensor MLX90614
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>
// Wire
#include <Wire.h>
// MLX90614
#include <Adafruit_MLX90614.h>

// MLX90614
Adafruit_MLX90614 mlx = Adafruit_MLX90614();
// MLX90614
float fAmbiente = 0;
float fObject = 0;

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "15-42";

void loop() {
  
  // isMLX90614
  isMLX90614();
  
  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay Infrared Temperature Sensor MLX90614
  isDisplayMLX90614();

  // Delay 2 Second
  delay( 2000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("Infrared Temperature MLX90614");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay MLX90614
void isDisplayMLX90614(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("Infrared Temperature MLX90614");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // MQ-3 Alcohol Detector
  screen.setCursor(0, 210);
  screen.println("Infrared Temperature MLX90614");
  screen.setCursor(0, 240);
  screen.print( "Ambiente: " );
  screen.setCursor(130, 240);
  screen.print( fAmbiente );
  screen.setCursor(200, 240);
  screen.println( "C" );
  screen.setCursor(0, 265);
  screen.print( "Object: " );
  screen.setCursor(130, 265);
  screen.print( fObject );
  screen.setCursor(200, 265);
  screen.println( "C" );
  
}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getgetHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

getMLX90614.ino

// Infrared Temperature Sensor MLX90614
// isMLX90614
void isMLX90614(){

  fAmbiente = mlx.readAmbientTempC();

  fObject = mlx.readObjectTempC();

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay( 100 );

  // Infrared Temperature Sensor MLX90614
  mlx.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
Project #15: Environment – MQ-3 Alcohol Detector – Mk41

——

#DonLucElectronics #DonLuc # #AHT20 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

MQ-3 Alcohol Detector

——

MQ-3 Alcohol Detector

——

MQ-3 Alcohol Detector

——

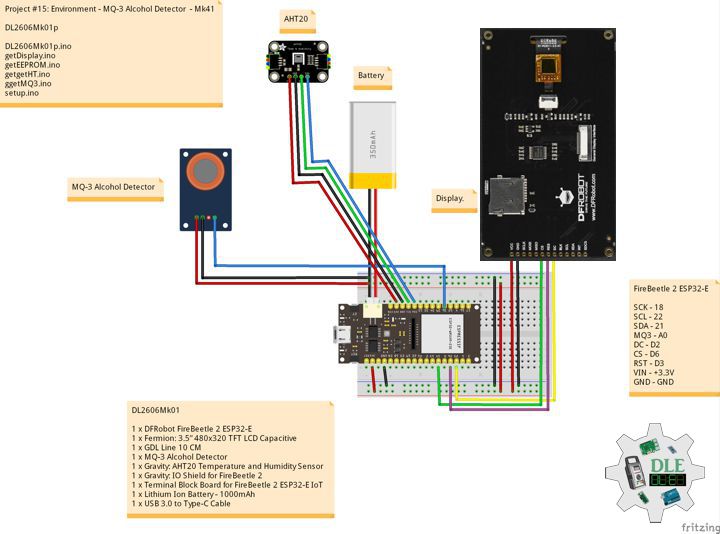
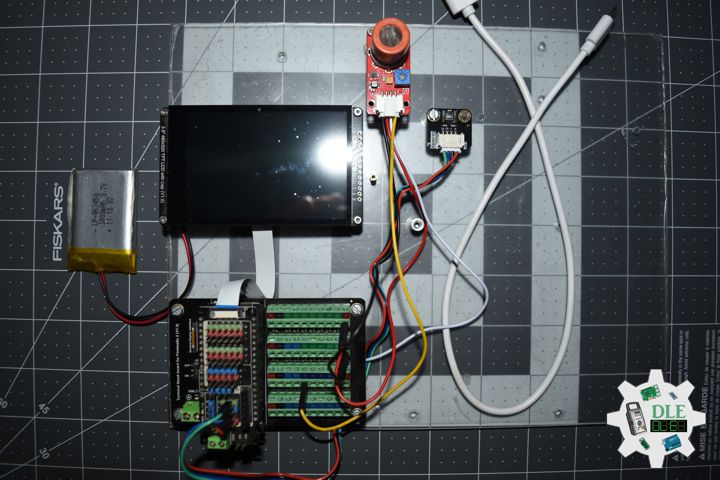
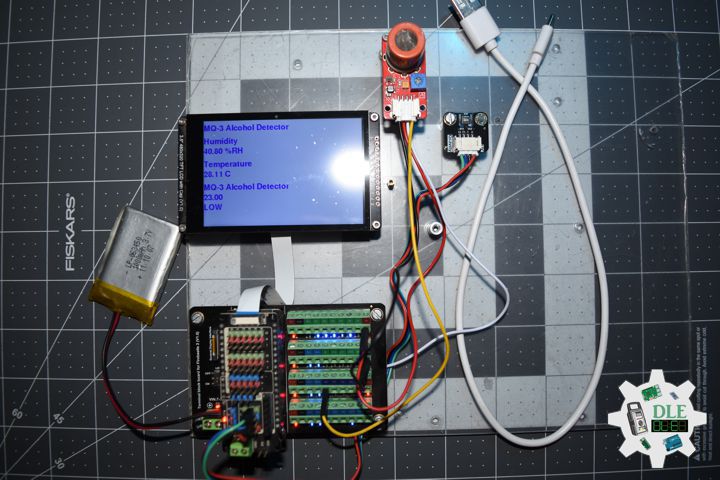
MQ-3 Alcohol Detector

The MQ-3 Alcohol Detector is an electronic sensor designed to detect the presence of alcohol vapors in the air, such as ethanol, methanol, and isopropyl alcohol. It operates using a sensitive metal oxide component whose resistance varies according to the ambient alcohol concentration, generating an analog signal that can be read by microcontrollers. The MQ-3 is easy to use, has a fast response time, and can detect alcohol concentrations across a wide range, making it a useful tool for both home and professional applications.

The MQ-3 Alcohol Detector is a widely used sensor for detecting the presence of alcohol vapors in the air, making it ideal for applications such as breathalyzers, vehicle security systems, access control projects, and environmental monitoring.

DL2606Mk01

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x MQ-3 Alcohol Detector
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2606Mk01p

DL2606Mk01p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment - MQ-3 Alcohol Detector - Mk41
15-41
DL2606Mk01p.ino
DL2606k01
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x MQ-3 Alcohol Detector
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>
// MQ-3 Alcohol Detector
#include <MQ3.h>

// MQ-3 Alcohol Detector
int iMQ3 = A0;
float iValMQ3 = 0;
// Value Limit
int iValLim = 400;
String sVal = ""; 

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "15-41";

void loop() {
  
  // isMQ3
  isMQ3();
  
  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay MQ-3 Alcohol Detector
  isDisplayMQ3();

  // Delay 2 Second
  delay( 2000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("MQ-3 Alcohol Detector");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay MQ3
void isDisplayMQ3(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("MQ-3 Alcohol Detector");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // MQ-3 Alcohol Detector
  screen.setCursor(0, 210);
  screen.println("MQ-3 Alcohol Detector");
  screen.setCursor(0, 240);
  screen.println( iValMQ3 );
  screen.setCursor(0, 270);
  screen.println( sVal );
  
}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

getMQ3.ino

// MQ-3 Alcohol Detector
// isMQ3
void isMQ3(){

  // iValMQ3
  iValMQ3 = analogRead( iMQ3 );

  // Value Limit
  if (iValMQ3 > iValLim) {

    sVal = "HIGH";

  } else {

    sVal = "LOW";

  }

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 20000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
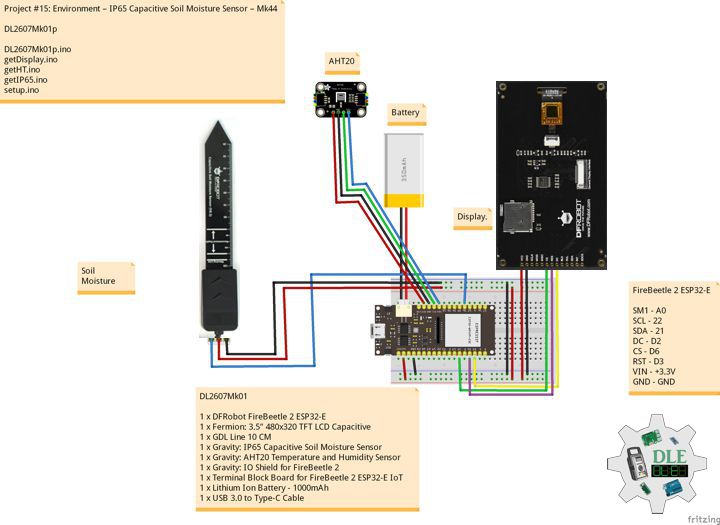
Project #15: Environment – MQ-135 Gas Sensor – Mk40

——

#DonLucElectronics #DonLuc #MQ135 #AHT20 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

MQ-135 Gas Sensor

——

MQ-135 Gas Sensor

——

MQ-135 Gas Sensor

——

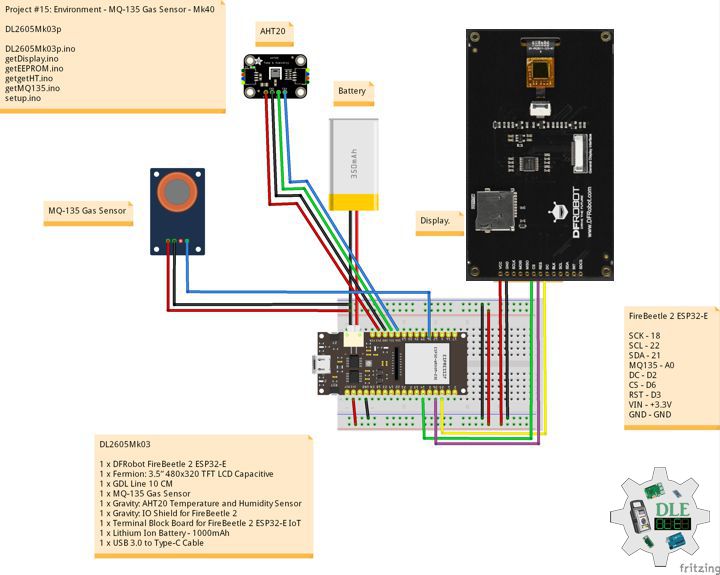
MQ-135 Gas Sensor

They are used in air quality control equipments for buildings. offices, home, etc, are suitable for detecting of NH3, NOx, Alcohol, Benzene, Smoke, CO2, Etc…

The sensor itself is enclosed in two layers of stainless steel mesh which ensures that the internal heating element does not cause an explosion since there may be flammable gases present in its working environment, and it also filters suspended particles so that only gases enter the chamber.

DL2605Mk03

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x MQ-135 Gas Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2605Mk03p

DL2605Mk03p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment - MQ-135 Gas Sensor - Mk40
15-40
DL2605Mk03p.ino
DL2605Mk03
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x MQ-135 Gas Sensor
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>
// MQ-135 Gas Sensor
#include <MQ135.h>

// MQ-135 Gas Sensor
int iMQ135 = A0;
int iValMQ135 = 0;

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "15-40";

void loop() {
  
  // isMQ135
  isMQ135();
  
  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay MQ-135
  isDisplayMQ135();

  // Delay 2 Second
  delay( 2000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("MQ-135 Gas Sensor");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay MQ135
void isDisplayMQ135(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("MQ-135 Gas Sensor");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // MQ7 Carbon Monoxide
  screen.setCursor(0, 210);
  screen.println("MQ-135 Gas Sensor");
  screen.setCursor(0, 240);
  screen.print( iValMQ135 );
  screen.setCursor(65, 240);
  screen.println( "ppm" );
  
}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getgetHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

ggetMQ135.ino

// MQ135
// isMQ135
void isMQ135(){

  iValMQ135 = analogRead( iMQ135 );

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Wait for the sensor to heat up for 20 seconds
  delay( 20000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
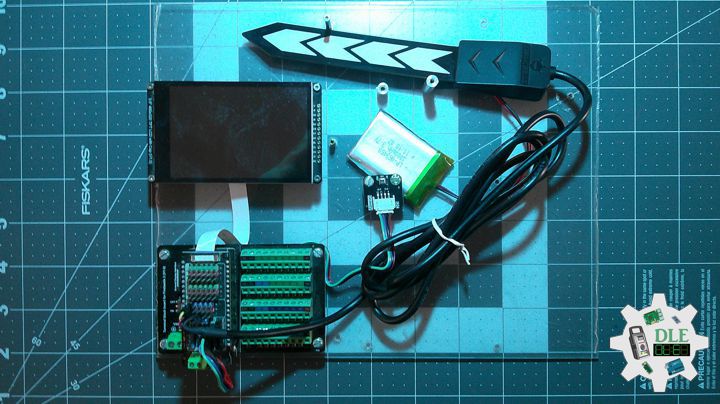
Project #15: Environment – Carbon Monoxide Sensor MQ7 – Mk39

——

#DonLucElectronics #DonLuc #CO #AHT20 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

Carbon Monoxide Sensor MQ7

——

Carbon Monoxide Sensor MQ7

——

Carbon Monoxide Sensor MQ7

——

Gravity: Analog CO Sensor (MQ7)

This is an Arduino Carbon Monoxide Sensor. It uses MQ7 probe to detect Carbon Monoxide (CO) concentrations in the air from 20 to 2000ppm. The sensitivity can be adjusted by the potentiometer. The output is proportional to the density of gas. You can use analog reading to read the data from this sensor.

DL2605Mk02

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Analog CO Sensor (MQ7)
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2605Mk02p

DL2605Mk02p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment - Carbon Monoxide Sensor MQ7 - Mk39
15-39
DL2605Mk02p.ino
DL2605Mk02
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Analog CO Sensor (MQ7)
1 x Gravity: AHT20 Temperature and Humidity Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// AHT20 Humidity and Temperature Sensor
#include <DFRobot_AHT20.h>

// MQ7 Carbon Monoxide
int iMQ7 = A0;
int iValMQ7 = 0;

// AHT20 Humidity and Temperature Sensor
DFRobot_AHT20 aht20;
// AHT20 Humidity and Temperature Sensor
float h = 0;
float t = 0;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "15-39";

void loop() {
  
  // isMQ7
  isMQ7();
  
  // AHT20 Humidity and Temperature Sensor
  isHT();

  // isDisplay CO
  isDisplayCO();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("Carbon Monoxide");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay CO
void isDisplayCO(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("Carbon Monoxide");
  // Humidity
  screen.setCursor(0, 70);
  screen.println("Humidity");
  screen.setCursor(0, 100);
  screen.print( h );
  screen.setCursor(65, 100);
  screen.println( "%RH" );
  // Temperature
  screen.setCursor(0, 140);
  screen.println("Temperature");
  screen.setCursor(0, 170);
  screen.print( t );
  screen.setCursor(65, 170);
  screen.println( "C" );
  // MQ7 Carbon Monoxide
  screen.setCursor(0, 210);
  screen.println("MQ7 Carbon Monoxide");
  screen.setCursor(0, 240);
  screen.print( iValMQ7 );
  screen.setCursor(65, 240);
  screen.println( "ppm" );
  
}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getgetHT.ino

// AHT20 Humidity and Temperature Sensor
void isHT(){

  if(aht20.startMeasurementReady(true)){

    // Humidity
    h = aht20.getHumidity_RH();
  
    // Temperature
    t = aht20.getTemperature_C();
    
   }
  
}

getMQ7.ino

// MQ7 Carbon Monoxide
// isMQ7
void isMQ7(){

  iValMQ7 = analogRead( iMQ7 );

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // AHT20 Humidity and Temperature Sensor
  aht20.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Delay 5 Second
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc
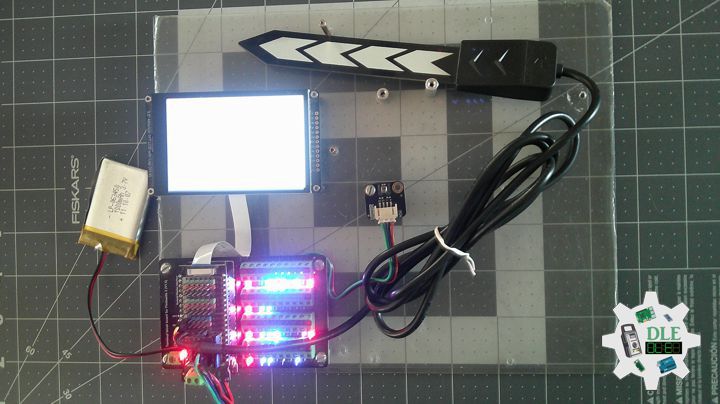
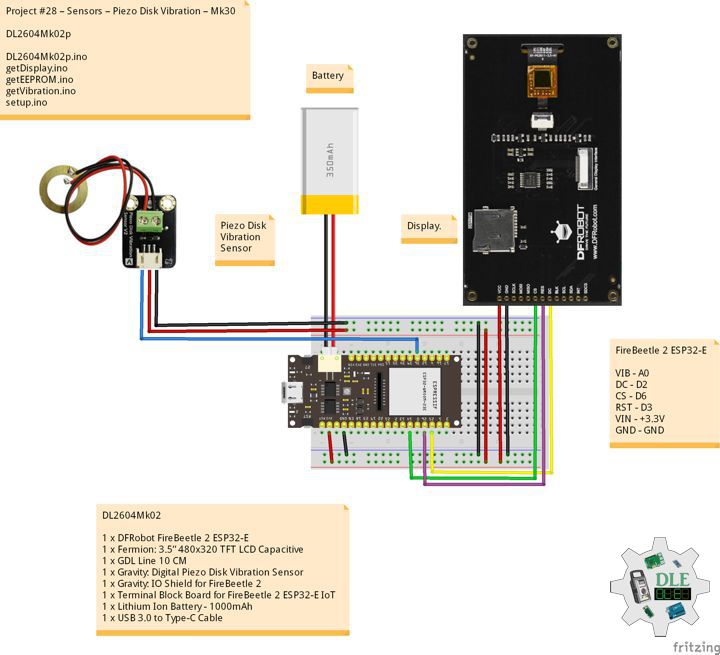
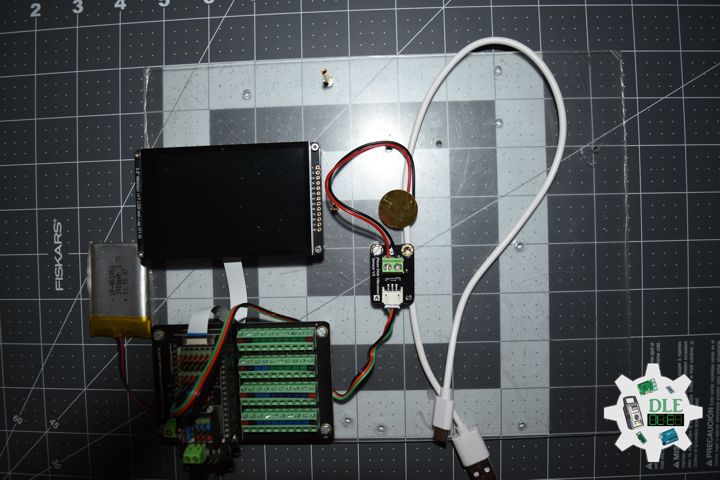
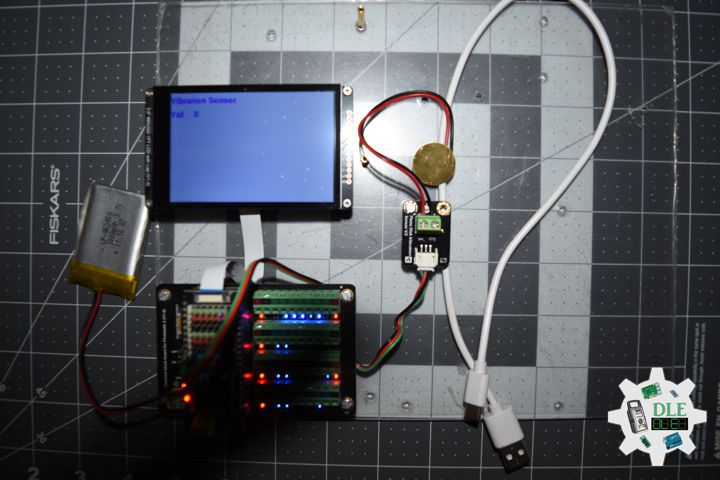
Project #28 – Sensors – Piezo Disk Vibration – Mk30

——

#DonLucElectronics #DonLuc #PiezoDiskVibration #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant

——

Piezo Disk Vibration

——

Piezo Disk Vibration

——

Piezo Disk Vibration

——

Gravity: Digital Piezo Disk Vibration Sensor

The DFRobot Vibration Sensor buffers a piezoelectric transducer that responds to strain changes by generating a measurable output voltage change which is proportional with the strength of vibration. So you can know the extent of vibration. Different from digital vibration sensor that only accounts times, this analog one can tell extent of vibration.

DL2604Mk02

1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Digital Piezo Disk Vibration Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable

DL2604Mk02p

DL2604Mk02p.ino

/****** Don Luc Electronics © ******
Software Version Information
Project #28 – Sensors – Piezo Disk Vibration – Mk30
28-30
DL2604Mk02p.ino
DL2604Mk02
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Gravity: Digital Piezo Disk Vibration Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// EEPROM Library to Read and Write EEPROM with Unique ID for Unit
#include "EEPROM.h"
// DFRobot Display GDL API
#include <DFRobot_GDL.h>

// Vibration Sensor
int iVibration = A0;
int iVal;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
// EEPROM Unique ID Information
#define EEPROM_SIZE 64
String uid = "";

// Software Version Information
String sver = "28-30";

void loop() {
  
  // Vibration Sensor
  isVibration();

  // isDisplay Vibration
  isDisplayVibration();

  // Delay 1 Second
  delay( 1000 );

}

getDisplay.ino

// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // Tilt Switch
  screen.setCursor(0, 60);
  screen.println("Vibration Senson");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );
  // EEPROM
  screen.setCursor(0, 150);
  screen.println("EEPROM");
  screen.setCursor(0, 180);
  screen.println( uid );

}
// isDisplay Vibration
void isDisplayVibration(){

  // DFRobot Display 320x480
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
  // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Vibration Senso
  screen.setCursor(0, 30);
  screen.println("Vibration Sensor");
  // Vibration Sensor
  screen.setCursor(0, 70);
  screen.print( "Val: " );
  screen.setCursor(70, 70);
  screen.println( iVal );
  
}

getEEPROM.ino

// isUID EEPROM Unique ID
void isUID()
{
  
  // Is Unit ID
  uid = "";
  for (int x = 0; x < 7; x++)
  {
    uid = uid + char(EEPROM.read(x));
  }
  
}

getVibration.ino

// Vibration Sensor
// is Vibration
void isVibration(){

  // Vibration Sensor
  // iVal
  iVal = analogRead( iVibration );

}

setup.ino

// Setup
void setup()
{
 
  // Delay
  delay( 100 );

   // EEPROM Size
  EEPROM.begin(EEPROM_SIZE);
  
  // EEPROM Unique ID
  isUID();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Version
  // EEPROM
  isDisplayUID();

  // Delay 5 Second
  delay( 5000 );

}

——

People can contact us: https://www.donluc.com/?page_id=1927

Consultant, R&D, Electronics, IoT, Teacher and Instructor

  • Programming Language
  • Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
  • IoT
  • Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
  • Robotics
  • Automation
  • Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
  • Unmanned Vehicles Terrestrial, Marine and UAV
  • Machine Learning
  • Artificial Intelligence (AI)
  • RTOS
  • Sensors, eHealth Sensors, Biosensor, and Biometric
  • Research & Development (R & D)
  • Consulting

Follow Us

Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/

Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
Elecrow: https://www.elecrow.com/share/sharepj/center/no/760816d385ebb1edc0732fd873bfbf13
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/

Don Luc