——
#DonLucElectronics #DonLuc #C4002 #Environment #FireBeetle2ESP32E #ESP32 #Display #IoT #Project #Fritzing #Programming #Electronics #Microcontrollers #Consultant
——
——
——
——
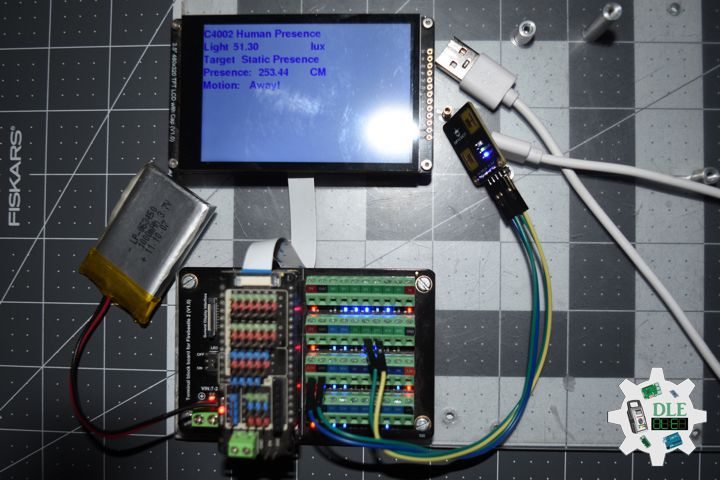
Fermion: C4002 mmWave Human Presence Sensor
Traditional PIR sensors only see movement. The C4002 sees people, whether walking, sitting, sleeping, or working. Beyond Traditional PIR Limits, delivers “True Presence” Automation with Micro-Motion Detection. Traditional PIR sensors often fail to detect stationary occupants, leading to inconvenient lighting deactivation. The Fermion: C4002 mmWave radar module resolves this by utilizing 24GHz FMCW technology to detect micro-motions (such as breathing and chest expansion). Capable of distinguishing between moving, stationary, and micro-moving targets within a 10×10 meter range, this module serves as a reliable core component for smart lighting, HVAC control, and security monitoring in Home Assistant and IoT systems.
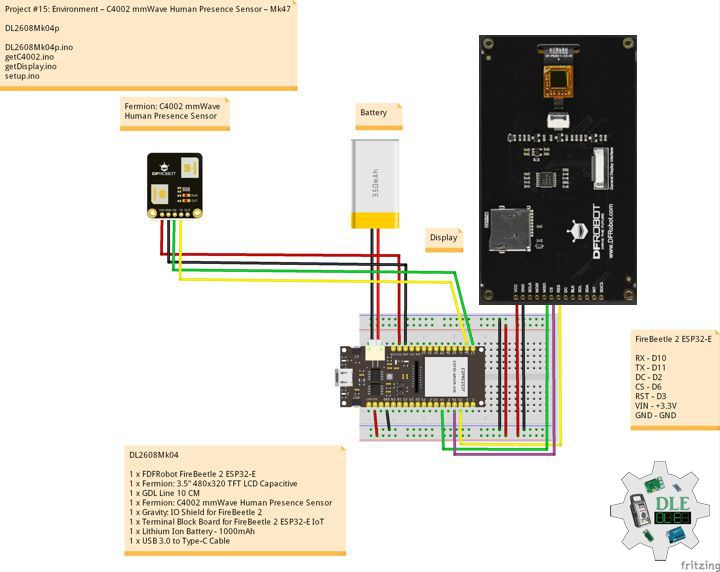
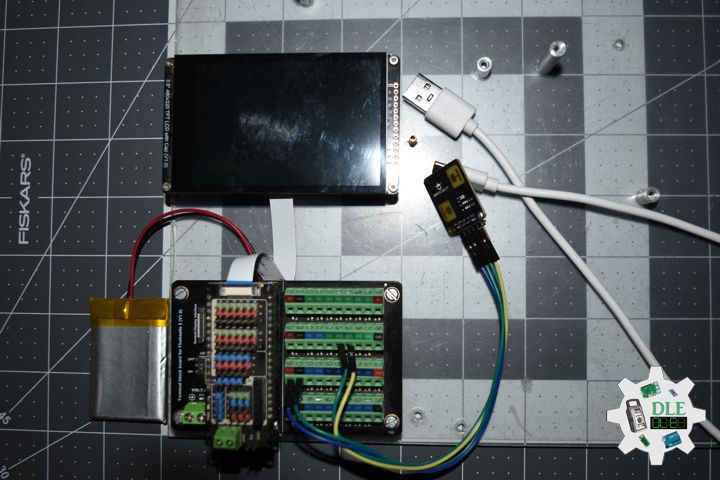
DL2608Mk04
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480×320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Fermion: C4002 mmWave Human Presence Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery – 1000mAh
1 x USB 3.0 to Type-C Cable
DL2608Mk04p
DL2608Mk04p.ino
/****** Don Luc Electronics © ******
Software Version Information
Project #15: Environment – C4002 mmWave Human Presence Sensor – Mk47
15-47
DL2608Mk04p.ino
DL2608Mk04
1 x DFRobot FireBeetle 2 ESP32-E
1 x Fermion: 3.5” 480x320 TFT LCD Capacitive
1 x GDL Line 10 CM
1 x Fermion: C4002 mmWave Human Presence Sensor
1 x Gravity: IO Shield for FireBeetle 2
1 x Terminal Block Board for FireBeetle 2 ESP32-E IoT
1 x Lithium Ion Battery - 1000mAh
1 x USB 3.0 to Type-C Cable
*/

// Include the Library Code
// DFRobot Display GDL API
#include <DFRobot_GDL.h>
// C4002 mmWave Human Presence
#include "DFRobot_C4002.h"

// C4002 mmWave Human Presence
DFRobot_C4002 c4002(&Serial1, 115200, /*D0*/ D11, /*D1*/ D10);
//float light;
String sLight;
// Get Target State
String sTarget;
// Get Presence distance gate target info
String sPreDis;
// Get motion distance gate index
String sMot;

// Defined ESP32
#define TFT_DC  D2
#define TFT_CS  D6
#define TFT_RST D3

/*dc=*/ /*cs=*/ /*rst=*/
// DFRobot Display 320x480
DFRobot_ILI9488_320x480_HW_SPI screen(TFT_DC, TFT_CS, TFT_RST);

// Software Version Information
String sver = "15-47";

void loop() {

  // isC4002
  isC4002();

  // isDisplay C4002
  isDisplayC4002();

  // Delay 0.1 Second
  delay( 100 );

}
getC4002.ino
// C4002 mmWave Human Presence
// isSetupC4002
void isSetupC4002(){

  // C4002 mmWave Human Presence
  // Initialize the C4002 sensor
  while (c4002.begin() != true) {
    Serial.println("C4002 begin failed!");
    delay(1000);
  }
  //Serial.println("C4002 begin success!");
  delay(50);

  // Set the run led to On

  if (c4002.setRunLedState(eLedOn)) {
    //Serial.println("Set run led success!");
  } else {
    Serial.println("Set run led failed!");
  }
  delay(50);

  // Set the out led to On
  if (c4002.setOutLedState(eLedOn)) {
    //Serial.println("Set out led success!");
  } else {
    Serial.println("Set out led failed!");
  }
  delay(50);

  // Set the Resolution mode to 20cm.
  // eResolution20Cm: This indicates that the resolution of the "distance gate"
  // is 20cm. With a resolution of 20 cm, it supports up to 25 distance gates,
  //with a maximum distance of 4.9 meters
  //c4002.setResolutionMode(eResolution20Cm);
  if (c4002.setResolutionMode(eResolution20Cm)) {
    //Serial.println("Set resolution mode success!");
  } else {
    Serial.println("Set resolution mode failed!");
  }
  delay(50);

  // Set the detect range to 0-200 cm
  uint16_t clostRange = 0;
  uint16_t farRange   = 200;
  if (c4002.setDetectRange(clostRange, farRange)) {    // Max detect range(0-1100cm)
    //Serial.println("Set detect range success!");
  } else {
    Serial.println("Set detect range failed!");
  }

  // Set the light threshold to 0 lux.range: 0-50 lux
  if (c4002.setLightThresh(0)) {
    //Serial.println("Set light threshold success!");
  } else {
    Serial.println("Set light threshold failed!");
  }
  delay(50);

  // Resolution mode:eResolution20Cm
  // Enable the 'distance gate'
  // Resolution mode:eResolution20Cm,This means that the number of 'distance gates'
  // we can operate is 25
  //disable : C4002_DISABLE, enable: C4002_ENABLE
  uint8_t gateState[25] = { C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE,
  C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE,
   C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE,
   C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE,
   C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE, C4002_ENABLE };

  // Operation motion distance gate
  if (c4002.configureGate(eMotionDistGate, gateState)) {
    Serial.println("Enable motion distance gate success!");
  }

  // Delay
  delay(50);

  // Operation presence distance gate
  if (c4002.configureGate(ePresenceDistGate, gateState)) {
    Serial.println("Enable presence distance gate success!");
  }

  // Delay
  delay(50);

  // Set the target disappear delay time to 1s,range: 0-65535s
  if (c4002.setTargetDisappearDelay(1)) {
    //Serial.println("Set target disappear delay time success!");
  } else {
    Serial.println("Set target disappear delay time failed!");
  }

  // Delay
  delay(50);

  // Set the report period to 10 * 0.1s = 1s
  if (c4002.setReportPeriod(10)) {
    //Serial.println("Set report period success!");
  } else {
    Serial.println("Set report period failed!");
  }

}
// isC4002
void isC4002(){

  // Get all the results of the C4002 sensor
  sRetResult_t retResult = c4002.getNoteInfo();

  if (retResult.noteType == eResult) {
    //Serial.println("------- Get all results --------");
    // get the light intensity
    float light = c4002.getLightIntensity();
    //Serial.print("Light: ");
    //Serial.print(light);
    //Serial.println(" lux");
    sLight = light;

    // get Target state
    eTargetState_t targetState = c4002.getTargetState();
    //Serial.print("Target state: ");
    if (targetState == eNoTarget) {

      //Serial.println("No Target");
      sTarget = "No Target";

    } else if (targetState == ePresence) {

      //Serial.println("Static Presence");
      sTarget = "Static Presence";

    } else if (targetState == eMotion) {

      //Serial.println("Motion");
      sTarget = "Motion";

    }

    // Get Presence distance gate target info
    sPresenceTarget_t presenceTarget = c4002.getPresenceTargetInfo();
    //Serial.print("Presence distance: ");
    //Serial.print(presenceTarget.distance);
    sPreDis = presenceTarget.distance;
    //Serial.println(" m");

    // Get motion distance gate index
    sMotionTarget_t motionTarget = c4002.getMotionTargetInfo();

    //Serial.print("Motion direction: ");
    if (motionTarget.direction == eAway) {

      //Serial.println("Away!");
      sMot = "Away!";

    } else if (motionTarget.direction == eNoDirection) {

      //Serial.println("No Direction!");
      sMot = "No Direction!";

    } else if (motionTarget.direction == eApproaching) {

      //Serial.println("Approaching!");
      sMot = "Approaching!";

    }
  }

}
getDisplay.ino
// DFRobot Display 320x480
// DFRobot Display 320x480 - UID
void isDisplayUID(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => black
  screen.fillScreen(0x0000);
  // Text Color => white
  screen.setTextColor(0xffff);
    // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // Don Luc Electronics
  screen.setCursor(0, 30);
  screen.println("Don Luc Electronics");
  // BME280 Environmental
  screen.setCursor(0, 60);
  screen.println("C4002 Human Presence");
  // Version
  screen.setCursor(0, 90);
  screen.println("Version");
  screen.setCursor(0, 120);
  screen.println( sver );

}
// isDisplay C4002
void isDisplayC4002(){

  // DFRobot Display 240x320
  // Text Display
  // Text Wrap
  screen.setTextWrap(false);
  // Rotation
  screen.setRotation(3);
  // Fill Screen => white
  screen.fillScreen(0xffff);
  // Text Color => blue
  screen.setTextColor(0x001F);
    // Font => Free Sans Bold 12pt
  screen.setFont(&FreeSansBold12pt7b);
  // TextSize => 1.5
  screen.setTextSize(1.5);
  // ENS160 Air Quality Sensor
  screen.setCursor(0, 30);
  screen.println("C4002 Human Presence");
  // Status
  screen.setCursor(0, 60);
  screen.print("Light ");
  screen.setCursor(70, 60);
  screen.print( sLight );
  screen.setCursor(250, 60);
  screen.println("lux");
  // Target
  screen.setCursor(0, 90);
  screen.print("Target ");
  screen.setCursor(90, 90);
  screen.println( sTarget );
  // Presence
  screen.setCursor(0, 120);
  screen.print("Presence: ");
  screen.setCursor(130, 120);
  screen.println( sPreDis );
  screen.setCursor(250, 120);
  screen.println( "CM" );
  //
  screen.setCursor(0, 150);
  screen.print("Motion: ");
  screen.setCursor(110, 150);
  screen.println( sMot );

}
setup.ino
// Setup
void setup()
{

  // Delay
  delay(100);

  Serial.begin(115200);

    // Delay
  delay( 100 );

  // C4002 mmWave Human Presence
  isSetupC4002();

  // Delay
  delay(100);

  // DFRobot Display 320x480
  screen.begin();

  // Delay
  delay( 100 );

  // DFRobot Display 320x480 - UID
  // Don Luc Electronics
  // Versioc
  isDisplayUID();

  // Delay
  delay( 5000 );

}
——
People can contact us: https://www.donluc.com/?page_id=1927
Consultant, R&D, Electronics, IoT, Teacher and Instructor
- Programming Language
- Single-Board Microcontrollers (PIC, Arduino, Raspberry Pi, Arm, Silicon Labs, Espressif, Etc…)
- IoT
- Wireless (Radio Frequency, Bluetooth, WiFi, Etc…)
- Robotics
- Automation
- Camera and Video Capture Receiver Stationary, Wheel/Tank , Underwater and UAV Vehicle
- Unmanned Vehicles Terrestrial, Marine and UAV
- Machine Learning
- Artificial Intelligence (AI)
- RTOS
- Sensors, eHealth Sensors, Biosensor, and Biometric
- Research & Development (R & D)
- Consulting
Follow Us
Luc Paquin – Curriculum Vitae – 2026
https://www.donluc.com/luc/LucPaquinCVEng2026Mk01.pdf
https://www.donluc.com/luc/
Web: https://www.donluc.com/
Web: https://www.jlpconsultants.com/
Facebook: https://www.facebook.com/neosteam.labs.9/
YouTube: https://www.youtube.com/@thesass2063
DFRobot: https://learn.dfrobot.com/user-10186.html
TikTok: https://www.tiktok.com/@luc.paquin8
Hackster: https://www.hackster.io/luc-paquin
LinkedIn: https://www.linkedin.com/in/jlucpaquin/
Don Luc